Our Work
Portfolio
Real systems we've designed, built, and deployed — spanning robotics, automation, controls, and mechanical engineering.
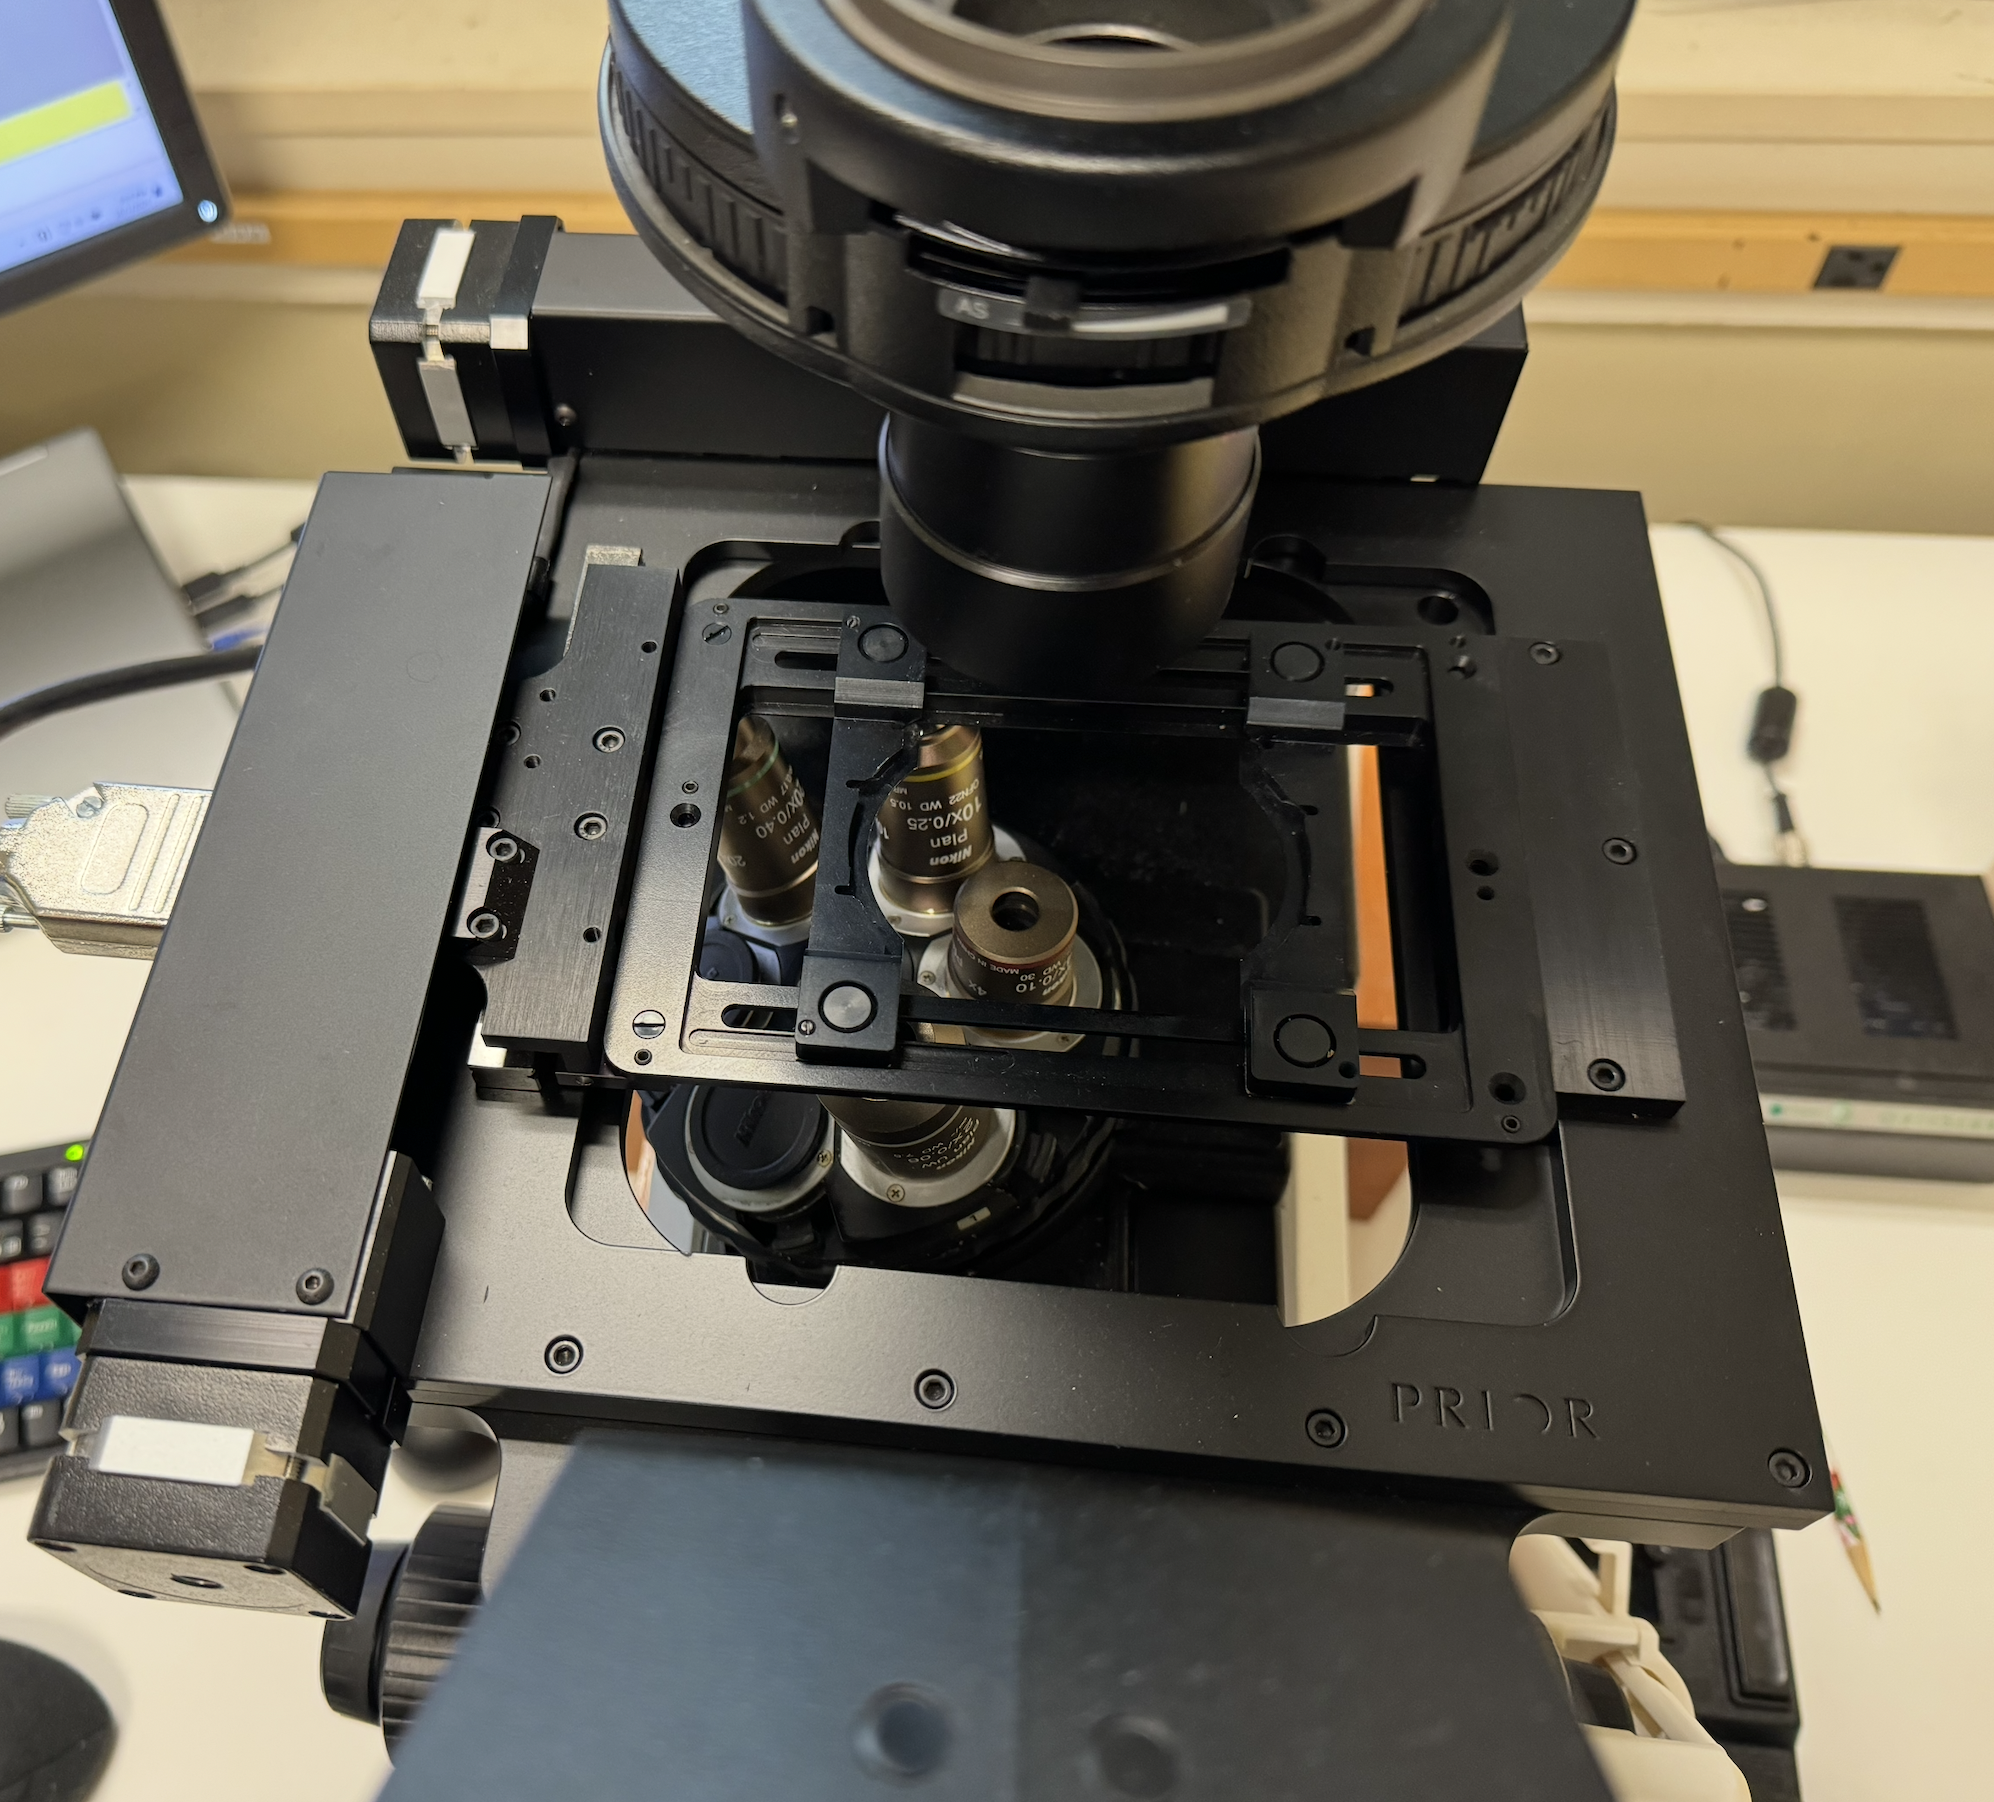
ROS 2-Controlled Robotic Imaging System for Smart Sample Scanning
Built a smart microscopy platform using ROS 2, NVIDIA Jetson, and a serial-controlled XY stage. Enabled autofocus and adaptive sample scanning through feedback-driven control and real-time video integration. Designed to automate data collection for training AI models focused on microscopic image analysis in agricultural applications.
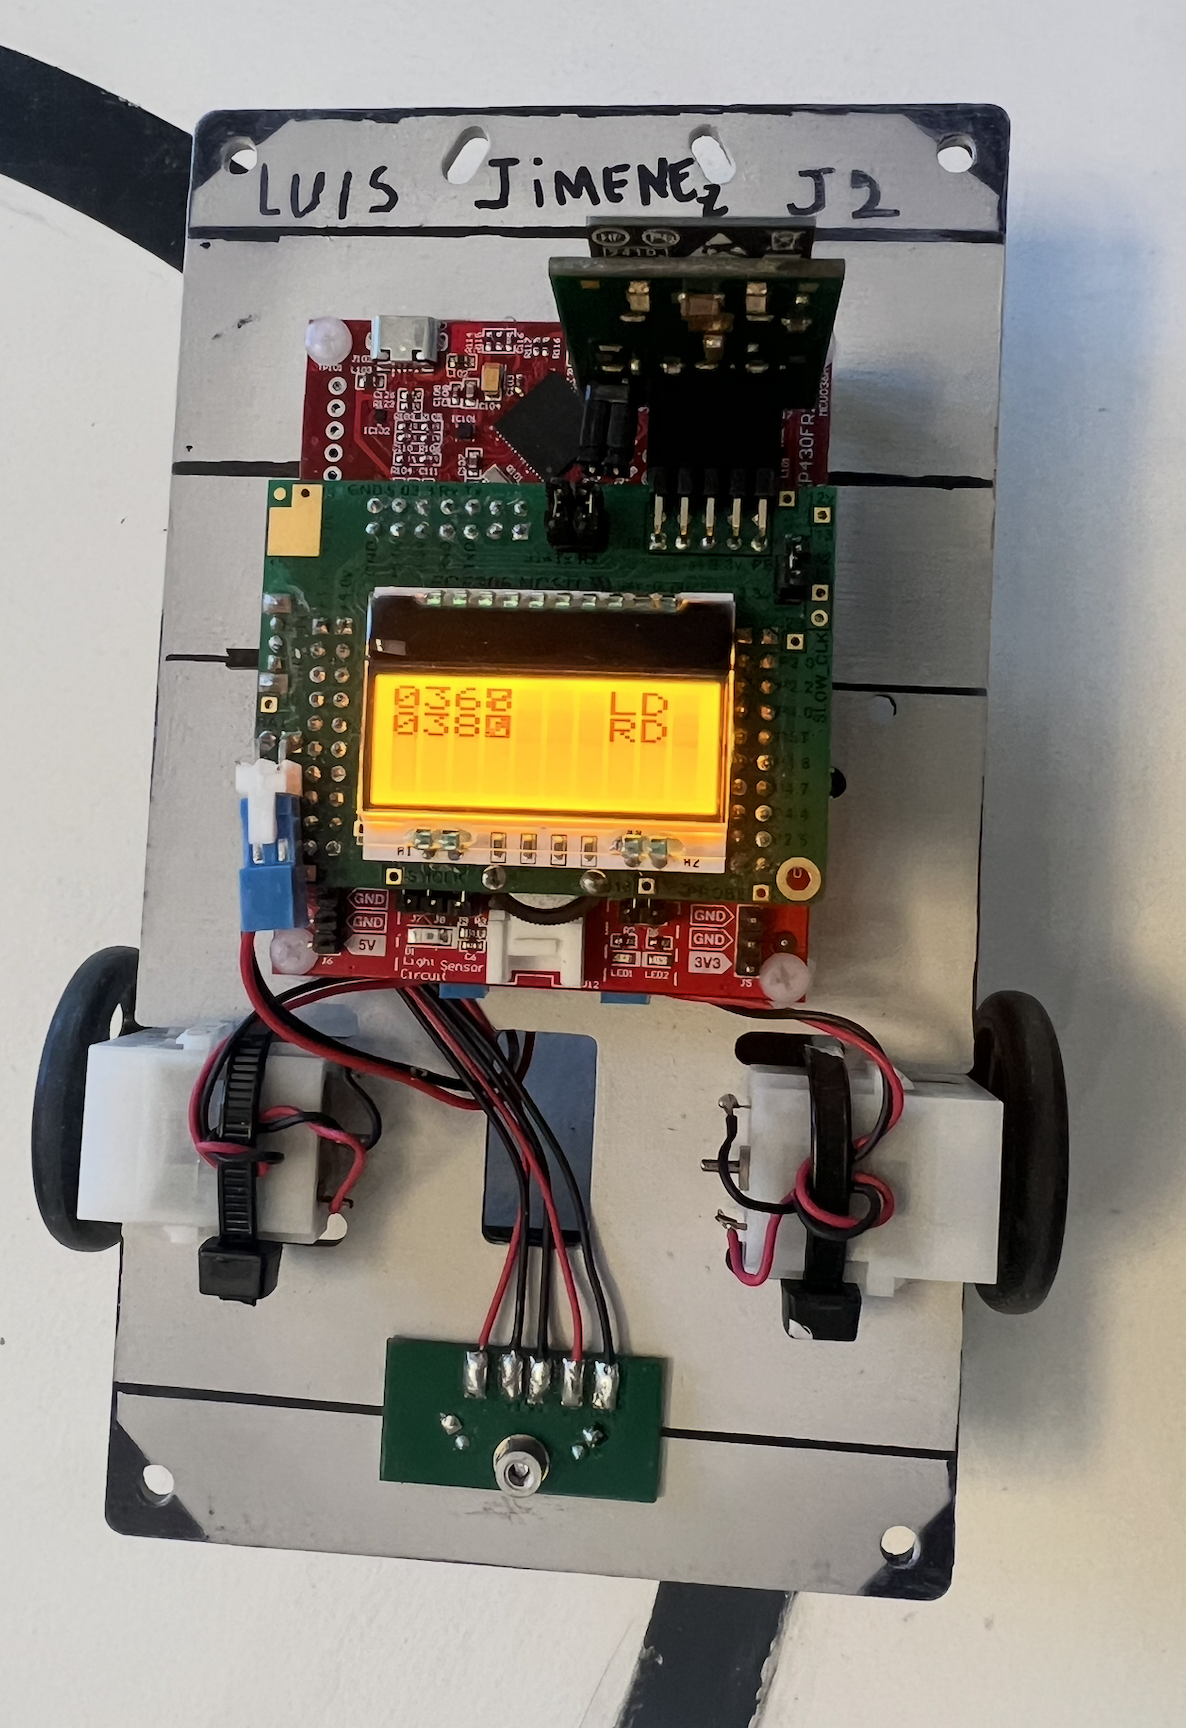
Autonomous Line-Following Car with WiFi Navigation and Real-Time Feedback
Built an intelligent vehicle using the MSP430 microcontroller to navigate an obstacle course via WiFi commands, then transition into full autonomous black line detection and following. Integrated real-time motor control, IR sensors, and serial communication to achieve 92% tracking accuracy, with WiFi latency reduced by 20%. The system included a custom LCD interface displaying live commands, timing, and event states.
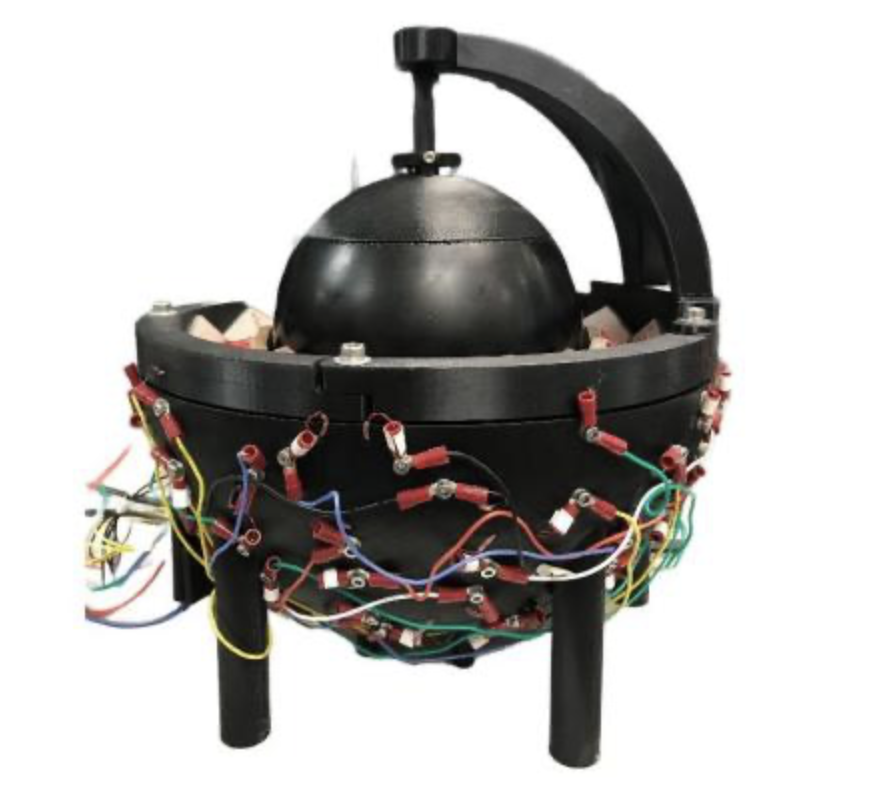
ML-Based Model Reference Adaptive Controller for a Nonlinear Robotic System
Developed an intelligent control system for a Permanent Magnet Synchronous Spherical Motor using neural networks to address nonlinearities and improve tracking accuracy. Designed a custom rolling bearing to reduce mechanical uncertainty and implemented a Model Reference Adaptive Controller (MRAC) in MATLAB/Simulink. Validated through simulation and hardware-in-the-loop experiments achieving a trajectory tracking MSE of 6.48 × 10⁻⁴.
Collaborative Bartending Robot - Human-Robot Interaction System
Developing a collaborative robotic system designed to assist humans in task-based workflows, using a bartending scenario as a demonstration of human-robot interaction. Built using ROS 2 and simulated in Gazebo Harmonic, enabling rapid prototyping of motion control, object manipulation, and task sequencing. The robot is designed to perform a complete workflow including object handoff, dynamic motion execution (shaking), and precise placement. While the use case is bartending, the underlying architecture directly applies to manufacturing, lab automation, and logistics environments.
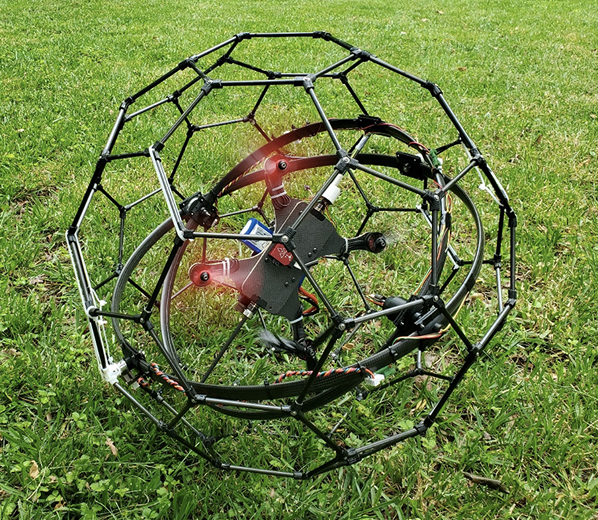
Mechanical Design — Spherical Rolling-Flying Vehicle (SRFV)
Designed the spherical carbon fiber cage and internal structural system for a hybrid rolling-flying robotic platform. The cage enables rolling locomotion while protecting the internal quadrotor system during operation. The design includes carbon fiber inner ring structures that support the gimbal-mounted propulsion system, allowing the vehicle to maintain stability while transitioning between rolling and aerial motion. This work demonstrates expertise in lightweight structural design, dynamic system constraints, and mechanical integration for advanced robotic platforms.
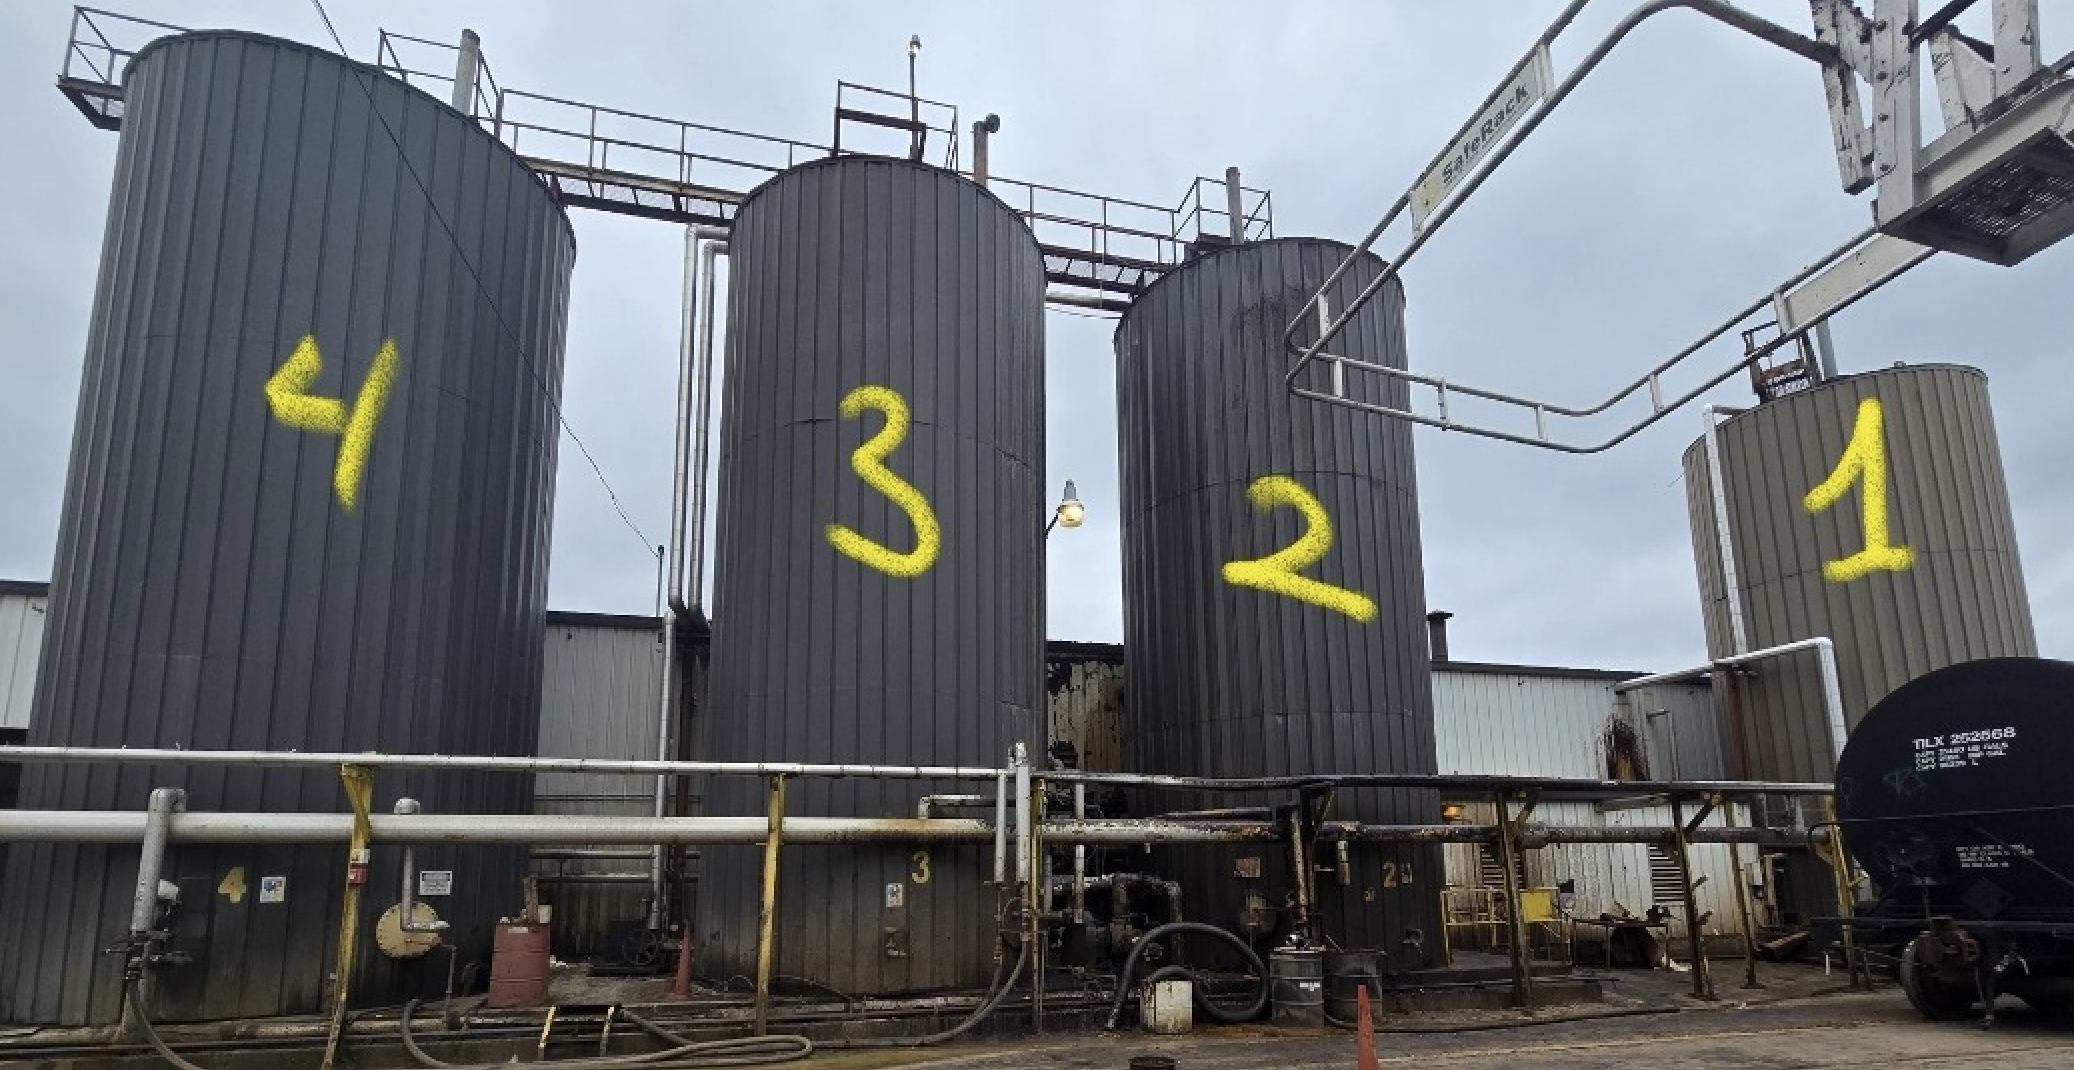
Smart Tank Level Monitoring System with PLC, Radar, and Ultrasonic Sensors
Engineered a real-time wax tank monitoring system using an Allen-Bradley PLC and Beijer HMI. Integrated radar sensors for vertical tanks and high-temperature ultrasonic sensors for horizontal tanks, with wireless PDW90 communication to centralize data across all units. Enabled real-time visualization, safety alerts, and operator training — improving operational reliability and tank-level accuracy across the facility.
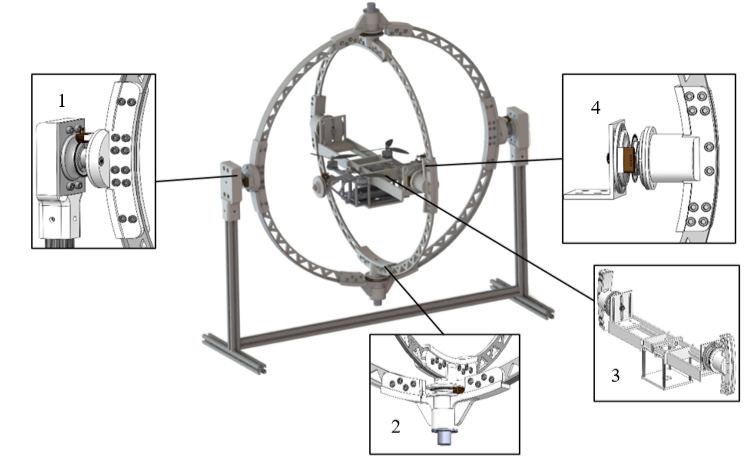
3-DOF Flight Gimbal System for Safe Flight Dynamics Testing
Designed and fabricated a three-degree-of-freedom gimbal system to safely test the flight dynamics of a Flying-Rolling Vehicle (FRV). Integrated slip rings and encoders to enable full 360° rotation and real-time tracking of roll, pitch, and yaw. Utilized finite element analysis (FEA) and optimized the structure using carbon fiber components for lightweight durability and reduced vibration.
Have a Project in Mind?
We're always open to discussing new robotics and automation challenges. Book a free 30-minute call to explore what we can build together.
Book a 30 Min Discovery Call